• Home
    • Copter
    • Plane
    • Rover
    • Blimp
    • Sub
    • AntennaTracker
    • Mission Planner
    • APM Planner 2
    • MAVProxy
    • Companion Computers
    • Developer
  • Downloads
    • Mission Planner
    • APM Planner 2
    • Advanced User Tools
    • Developer Tools
    • Firmware
  • Community
    • Support Forums
    • Facebook
    • Developer Chat (Discord)
    • Developer Voice (Discord)
    • Contact us
    • Getting involved
    • Commercial Support
    • Development Team
    • UAS Training Centers
  • Stores
  • About
    • News
    • History
    • License
    • Trademark
    • Acknowledgments
    • Wiki Editing Guide
    • Partners Program
  • Offline
Plane Logo
  • Introduction to Plane
  • Choosing an Autopilot
  • Ground Control Stations
  • First Time Setup
  • First Flight and Tuning
  • QuadPlane Setup and Operation
  • Mission Planning
  • If A Problem Arises
  • Advanced Configuration
  • Peripheral Hardware
    • ADS-B Receiver
    • Airspeed Sensor
    • AIS (Automatic Identification System)
    • Barometer (external)
    • BlackBox Logger using an AutoPilot
    • Button Inputs
    • Buzzer
    • Cameras & Gimbals
    • Companion Computers
    • Crop Sprayer
    • Display (Onboard)
    • Drive Calculator Motor/Propeller Analyzer
    • DroneCAN Adapter Node
    • DroneCAN Peripherals
    • ESCs and Motors
    • Ethernet Adapters and Switches
    • External AHRS Systems
    • First Person View Video
    • Fuel Flow and Level Sensors
    • Generators
    • GPS/Compass
      • GPS/Compass
      • RTK GPS
        • AeroAtoms Orbit Base
        • AeroAtoms Orbit Nano RTK (UART / DroneCAN)
        • ArduSimple RTK GPS simpleRTK2B Budget (u-blox ZED-F9P)
        • ArduSimple RTK GPS simpleRTK3B Pro (Septentrio Mosaic-X5)
        • ArduSimple RTK GPS simpleRTK3B Compass (Unicore UM982, Dual antenna heading)
        • ArduSimple RTK GPS simpleRTK 4 Optimum (u-blox ZED-X20P)
        • ARK MOSAIC-X5 RTK GPS
        • ARK RTK Base
        • ARK RTK F9P
        • ARK RTK GPS L1 L5
        • ARK X20 RTK GPS
        • Blicube RTK GPS (Single Unit Moving Baseline NMEA)
        • CUAV C-RTK 9P RTK Receiver
        • CUAV C-RTK 9Ps RTK Receiver
        • CUAV C-RTK2 PPK and RTK receiver
        • CUAV C-RTK2 HP Heading and RTK receiver
        • DATAGNSS H10P RTK/Compass Receiver
        • DATAGNSS GEM1305 RTK Receiver
        • DATAGNSS NANO RTK Receiver
        • Emlid Reach RTK Receiver
        • CubePilot HERE 3/3+ DroneCAN RTK GPS/IMU/Compass
        • CubePilot HERE 4 DroneCAN RTK GPS/IMU/Compass (see note below)
        • CubePilot Here+ RTK Base/Rover Receiver
        • CubePilot HEREPRO DroneCAN F9P RTK GPS/Compass
        • Freefly RTK GPS Ground Station
        • Foxteck AEROFOX F9P-RTK
        • GNSS.Store UM980 ultraLight RTK GNSS Smart Antenna
        • GNSS.Store ZED-X20P ultraLight RTK GNSS Smart Antenna
        • GNSS.Store mosaic-X5 ultraLight RTK GNSS Smart Antenna
        • GNSS.Store mosaic-g5 ultraLight RTK GNSS Smart Antenna
        • Hitec PositionPro GNSS
        • Holybro DroneCAN H-RTK F9P Rover
        • Holybro DroneCAN H-RTK F9P Helical
        • Holybro RTK F9P Family
        • Holybro RTK M8P
        • Holybro RTK F9P Ultralight
        • Holybro RTK ZED-F9P Rover (RM3100 Compass, Barometer, IP66 Waterproof)
        • Holybro RTK NEO-F9P Family
        • Holybro RTK Unicore UM982 GPS (Dual Antenna Heading)
        • Holybro RTK mosaic-H GPS (Dual Antenna Heading)
        • LOCOSYS HAWK R1 RTK GNSS / R2 RTK GNSS + Compass
        • Navisys GR-901U ZED-F9P RTK base for Ground Station
        • Navisys GE-920 Dual-Antenna RTK
        • Navisys GM-905 RTK / CLAS GNSS Module
        • Qiotek DroneCAN RTK-F9P GPS
        • Swift Navigation's Piksi Multi RTK GPS Receiver
        • Septentrio AsteRx-m UAS RTK GPS
        • Synerx MDU-2000 RTK + LTE GPS
        • Trimble BD930 RTK GNSS
        • Trimble PX-1 RTX GNSS+INS
      • Moving Baseline (GPS for Yaw) Capable
        • AeroAtoms Orbit Neo / Neo Plus RTK
        • Ark RTK GPS <https://arkelectron.com/product/ark-rtk-gps/> Blicube RTK GPS (Single Unit Moving Baseline)
        • CUAV C-RTK 9P RTK Receiver
        • CUAV C-RTK 9Ps RTK Receiver
        • CUAV C-RTK2 PPK and RTK receiver
        • CUAV C-RTK2 HP Heading and RTK receiver
        • CubePilot HERE 4 DroneCAN RTK GPS/IMU/Compass
        • CubePilot HEREPRO DroneCAN RTK GPS/Compass
        • Foxteck AEROFOX F9P-RTK
        • Freefly RTK GPS Ground Station
        • Holybro DroneCAN H-RTK F9P Rover
        • Holybro DroneCAN H-RTK F9P Helical
        • Holybro RTK F9P Family
        • Holybro RTK F9P Ultralight
        • Holybro RTK ZED-F9P Rover (RM3100 Compass, Barometer, IP66 Waterproof)
        • Holybro RTK NEO-F9P Family
        • Holybro RTK Unicore UM982 GPS (Dual Antenna Heading)
        • Holybro RTK mosaic-H GPS (Dual Antenna Heading)
        • Navisys GM-905 RTK / CLAS GNSS Module
        • Qiotek DroneCAN RTK-F9P GPS
        • Synerx MDU-2000 RTK + LTE GPS
      • GPS Type Detection
      • GPS Auto Configuration
      • GPS Driver Options
      • GPS Auto Switch
      • GPS Jamming Mediation
      • Advanced Uses
    • Grippers
    • Joystick or Gamepad
    • Landing Gear/ Retractable Camera Mount
    • LEDs (external)
    • On-Screen Display (OSD)
    • Optical Flow Sensor
    • Parachute
    • Power Modules
    • Power Tether
    • PPM Encoder
    • Radio Control Systems
    • Rangefinders (Sonar, Lidar, Depth Cameras)
    • Relay Switch
    • Remote Id (aka Drone Id)
    • RPM Sensor
    • Safety Switch
    • Servos and Actuators
    • Smart Batteries
    • Telemetry Radio
    • Temperature Sensors
    • Video (High Definition)
    • Winch
  • Additional Information
  • User Alerts


Individual Partners SWAG Shop
Plane
  • Peripheral Hardware
  • GPS/Compass (landing page)
  • Navisys GM-905 RTK / CLAS GNSS Module
  • Edit on GitHub

Navisys GM-905 RTK / CLAS GNSS Module
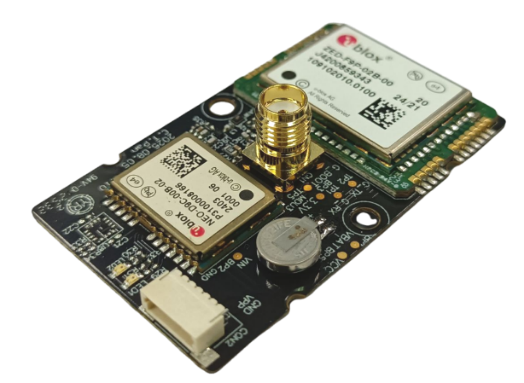
../_images/navisys_gm-905.png

The Navisys GM-905 is an L1/L2 dual-band RTK GNSS module based on the u-blox ZED-F9P receiver, with an SMA connector for an external helical antenna and a 6-pin UART connector. It is used in ArduPilot with the u-blox GPS driver. Two variants are available:

  • GM-9051 (RTK): ZED-F9P only. Can be used as an RTK rover with corrections from a ground station, or as a pair for Moving Baseline (GPS for Yaw).

  • GM-9056 (CLAS): ZED-F9P plus a u-blox NEO-D9C receiver for the free QZSS CLAS (Centimeter-Level Augmentation Service) L6 signal. This gives centimeter-level positioning without a base station or ground station correction link, inside the CLAS service area (Japan).

Specifications

  • Receivers

    • u-blox ZED-F9P dual-band GNSS (all variants)

      • GPS L1C/A L2C, GLONASS L1OF L2OF, Galileo E1-B/C E5b, BeiDou B1I B2I, QZSS L1C/A L1S L2C, SBAS

      • RTK accuracy 0.01 m + 1 ppm CEP (u-blox specification)

      • Update rate up to 7 Hz (PVT, four constellations)

      • RTK convergence in 10 s (multi-GNSS)

      • Spoofing detection and jamming / interference indicator

    • u-blox NEO-D9C QZSS L6 correction receiver (GM-9056 only)

      • CLAS horizontal accuracy 4 cm CEP, vertical 8 cm R50

      • CLAS convergence time < 70 s

      • CLAS update rate up to 5 Hz (four constellations)

  • Interface

    • 6-pin, 1.0 mm pitch connector (UART1, UART2 / 1PPS)

    • UART TTL, 460800 bps by default

    • SMA female connector for an L1/L2 (GM-9051) or L1/L2/L6 (GM-9056) helical antenna

  • Power

    • 5 V

    • Built-in backup battery

  • Other

    • Optional RTK (red) and GNSS (green) status LEDs (suffix L or P)

    • Optional 1PPS output (suffix P)

    • Operating temperature: -40 ~ 85 °C (battery: -10 ~ 60 °C)

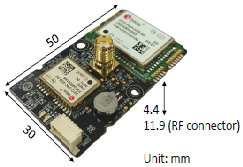
    • Dimensions: 30 x 50 x 11.9 mm (including SMA connector)

    • 2 mounting holes

../_images/navisys_gm-905_dimensions.png

Pinout

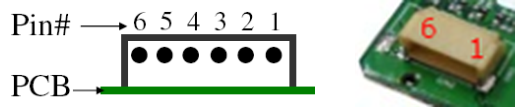
../_images/navisys_gm-905_pinout.png

Pin

Name

Function

Type

1

GND

Ground

Power

2

VCC

Power supply (5 V)

Power

3

TXD

UART1 transmit (TTL), to autopilot RX

Output

4

RXD

UART1 receive (TTL), from autopilot TX

Input

5

TX2

UART2 transmit, for moving baseline (1PPS on suffix P)

Output

6

RX2

UART2 receive, for moving baseline (NC on suffix P)

Input

Connect pins 1 to 4 to a serial (GPS) port of the autopilot. Pins 5 and 6 are only needed for a moving baseline setup with a direct UART2 link (see below).

Note

The GM-905 pin order (GND, VCC, TXD, RXD) is different from the Pixhawk-standard GPS port (5V, TX, RX, SCL, SDA, GND). A custom cable is needed. Connect GM-905 TXD to the autopilot RX and GM-905 RXD to the autopilot TX.

ArduPilot Configuration

The GM-905 has been tested with ArduPilot by Navisys.

RTK or CLAS Rover (single module)

When connected to the GPS1 port (SERIAL3) of a Pixhawk-standard autopilot:

  • SERIAL3_PROTOCOL = 5 (GPS)

  • GPS1_TYPE = 1 (AUTO) or 2 (u-blox)

  • GPS_AUTO_CONFIG = 1 (AutoConfig Serial)

The baud rate is detected automatically, and ArduPilot configures the module for UBX binary output.

GM-9051: RTK corrections are sent from the ground station to the module through the autopilot. See RTK GPS Correction (Fixed Baseline).

GM-9056: CLAS corrections are received and applied inside the module, so no correction link is needed. When CLAS has converged, the GPS status is shown as RTK Float or RTK Fixed. Keep GPS1_RATE_MS at the default of 200 (5 Hz), which is the maximum CLAS update rate with four constellations.

Warning

On the GM-9056, do not set GPS_AUTO_CONFIG = 3. This setting clears all receiver configuration not set by ArduPilot, which can remove the factory settings needed for CLAS.

Note

With GPS_AUTO_CONFIG = 1 and the default GPS_SAVE_CFG = 2, ArduPilot changes the UART1 settings of the module (baud rate and UBX output) and saves them to the module. If the module is later used with other software that expects the factory NMEA output, it must be reconfigured, for example with u-center.

Moving Baseline (GPS for Yaw, GM-9051)

Two GM-9051 modules can provide GPS yaw as described in GPS for Yaw (aka Moving Baseline). Connect each module to its own autopilot serial port, for example SERIAL3 and SERIAL4, and set:

  • SERIAL3_PROTOCOL = 5 (GPS)

  • SERIAL4_PROTOCOL = 5 (GPS)

  • GPS1_TYPE = 17 (u-blox Moving Baseline Base)

  • GPS2_TYPE = 18 (u-blox Moving Baseline Rover)

  • GPS_AUTO_CONFIG = 1

  • GPS_AUTO_SWITCH = 1 (do not use 2 (Blend) with Moving Baseline)

  • AHRS_EKF_TYPE = 3 (EKF3)

  • EK3_SRC1_YAW = 2 (GPS) or 3 (GPS with Compass Fallback)

  • GPS1_POS_X/Y/Z and GPS2_POS_X/Y/Z: antenna positions of the base and rover modules. See Sensor Position Offset Compensation.

By default, the RTCM data from the base module goes to the rover module through the autopilot. Alternatively, connect the UART2 pins of the two modules with a cross-over cable (pin 5 of one module to pin 6 of the other, both ways) and set GPS_DRV_OPTIONS = 1 so that the RTCM data goes directly over UART2. The UART2 link cannot be used on suffix P modules, because pin 5 is the 1PPS output and pin 6 is not connected.

More Information

  • Navisys Official Website

Previous Next

Questions, issues, and suggestions about this page can be raised on the forums. Issues and suggestions may be posted on the forums or the Github Issue Tracker.

Creative Commons License© Copyright 2024, ArduPilot Dev Team.