Smartmicro T132 Drone Altimeter
The Smartmicro T132 is a radar-based distance sensor with a DroneCAN interface. It can be used as a rangefinder with ArduPilot.
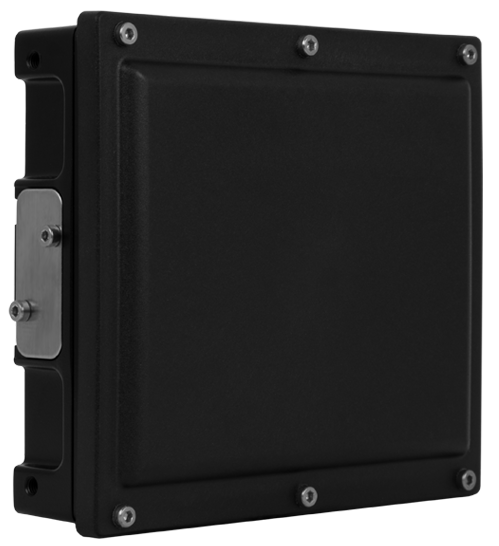
The T132 supports altitude measurements up to 175 m and communicates over DroneCAN using a 1 Mbit/s CAN bus. The sensor uses 29-bit CAN identifiers and has an update interval of 55 ms. Once configured, the sensor publishes distance measurements at approximately 18.2 Hz.
The T132 is particularly suitable for altitude measurement on UAVs, including operation in GNSS-denied environments.
Hardware Specifications
Altitude: up to 175 m possible
Automatic dual mode operation (medium/long range mode)
Operates in 76-77 GHz band approved for altimeter operation in Europe
Made in Germany, specially designed for European drone manufacturers
ITAR free, not dual-use classified
Mature hardware, in full production, available in high volume
High electromagnetic susceptibility robustness: difficult to jam
Low observability (narrow beam, short dwell time)
Interface: DroneCAN
CAN bitrate: 1 Mbit/s
CAN identifiers: 29-bit
Update rate: approximately 18.2 Hz
Supply voltage: DC 8-32 V
Power consumption: 3.75-5 W
Weight: 274 g
Dimensions: 94.7 x 84.4 x 26.4 mm (plus connector)
Connector: Hirose LF10 series
Operating temperature: -40 to +85 °C
Protection: IP67
Internal CAN termination
Hardware Setup
Sensor Setup
For optimal performance, the antenna of the radar should be parallel to the surface of the earth during normal flight.
The antenna is located directly behind the black plastic radome. The black plastic surface should therefore face down when the sensor is used for altitude measurement.
The word “TOP” on the sensor label and the accompanying arrow should point either in the direction of flight or directly opposite the direction of flight. The arrow should not point perpendicular to the direction of flight.
The sensor may be mounted behind a flat plastic surface, for example inside the fuselage, provided that the surface is radar transparent.
Wiring
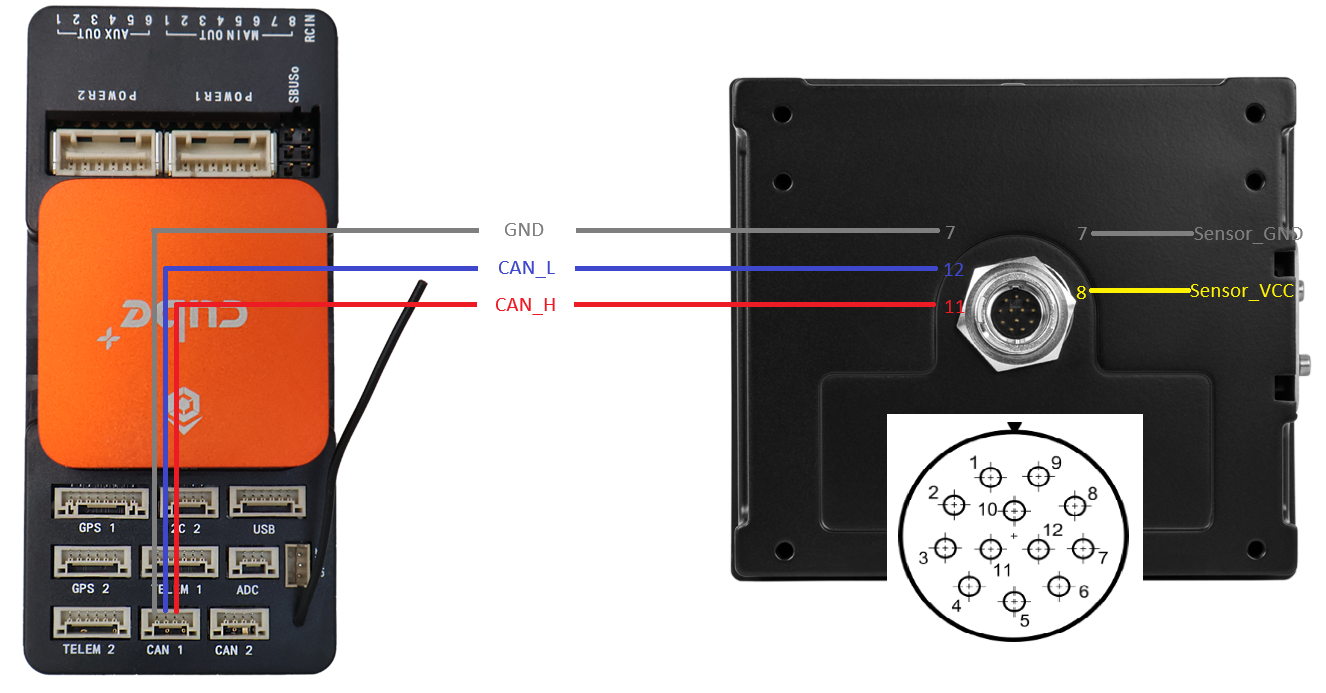
The sensor connector is a 12-pin male bayonet type connector (waterproof IP67, series LF10WBRB-12PD, manufacturer Hirose, Japan).
Connect the following signals to the flight controller:
CAN_H
CAN_L
GND
Also connect these wires to a power supply:
Power supply
GND
Warning
Make sure that the complete CAN bus has correct termination. The T132 contains an internal termination resistor, so the CAN bus topology must be taken into account when connecting additional CAN devices.
Smartmicro does not provide a cable that connects to Pixhawk-standard CAN bus connectors out of the box. But different cable options with D-Sub-9 connector or as “Open Wire” are available.
Firmware
The T132 is supplied with firmware and does not require an initial sensor configuration for normal operation.
Future firmware updates can be performed using Smartmicro proprietary software over the CAN interface.
Connecting to the Autopilot
Connect the T132 to a CAN port on the flight controller.
The T132 uses DroneCAN, so the CAN port can be shared with other DroneCAN devices on the same CAN bus.
For example, when using CAN1, configure:
CAN_P1_DRIVER = 1
CAN_P1_BITRATE = 1000000
CAN_D1_PROTOCOL = 1 (DroneCAN)
The rangefinder must then be configured using:
RNGFND1_TYPE = 24 (DroneCAN)
RNGFND1_ADDR = 0
RNGFND1_MIN = 1
RNGFND1_MAX = 175
A reboot is required after changing the rangefinder type or the CAN configuration.
Sensor Operation
The measured altitude is perpendicular to the radome of the sensor. When the vehicle rolls or pitches, the measured altitude is too high and must be compensated by roll and pitch angles.
The radar automatically operates in medium- and long-range modes according to the measurement conditions.
If the sensor is unable to determine the current altitude (too high, too low or occluded radome) this is signaled as (DroneCAN) reading_type=undefined.
Testing the Sensor
After configuring the CAN interface and rangefinder, reboot the flight controller.
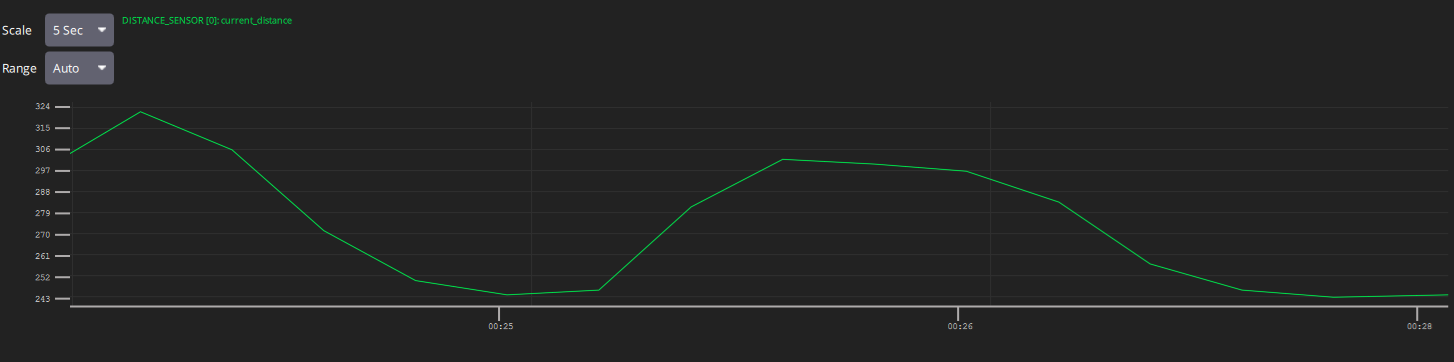
The T132 should then be detected automatically as a DroneCAN rangefinder. Measurements are shown in the MAVLink Inspector like this:
Troubleshooting
Sensor is not detected
Check the following:
The T132 is supplied with 8-32 V DC.
CAN_H and CAN_L are connected correctly.
The CAN bitrate is set to 1 Mbit/s.
CAN_P1_DRIVER is configured correctly.
CAN_D1_PROTOCOL is set to 1 (DroneCAN).
The flight controller has been rebooted after changing the CAN parameters.
The CAN bus has appropriate termination.
The T132 is connected to the same CAN bus as the configured CAN interface.
No rangefinder measurement
Check:
RNGFND1_TYPE is set to 24 (DroneCAN).
RNGFND1_MIN is configured correctly.
RNGFND1_MAX is configured correctly.
RNGFND1_ADDR matches the DroneCAN sensor ID when multiple sensors are connected.
The radar radome has an unobstructed view.
The target is within the specified measurement range.