SIYI Camera Gimbals

Siyi manufactures a range of camera gimbals that are compatible with ArduPilot using a custom protocol via serial or Ethernet. The lineup includes:
Warning
The Siyi A2 is not supported.
Where to Buy
These gimbals can be purchased directly from SIYI
Connecting to the Autopilot


Connect the gimbal’s RX, TX and GND pins to one of the autopilot’s serial ports as shown above.
Connect with a ground station and set the following parameters. The params below assume the autopilot’s telem2 port is used and the Camera1 control instance:
SERIAL2_PROTOCOL to 8 (“SToRM32 Gimbal Serial”)
SERIAL2_BAUD to “115” for 115200 bps
MNT1_TYPE to “8” (“Siyi”) and reboot the autopilot
MNT1_PITCH_MIN to -90
MNT1_PITCH_MAX to 25
MNT1_YAW_MIN to -135
MNT1_YAW_MAX to 135
MNT1_RC_RATE to 90 (deg/s) to control speed of gimbal when using RC targeting
RC6_OPTION = 213 (“Mount Pitch”) to control the gimbal’s pitch angle with RC channel 6
RC7_OPTION = 214 (“Mount Yaw”) to control the gimbal’s yaw angle with RC channel 7
RC8_OPTION = 163 (“Mount Yaw Lock”) to switch between normal yaw operation and locking mount heading with RC channel 8 (in RC Targeting mode only).
CAM1_TYPE = 4 / “Mount (Siyi)” to allow control of the camera
Optionally these auxiliary functions are also available:
RC9_OPTION = 9 (“Camera Trigger”) to take a picture
RC9_OPTION = 166 (“Camera Record Video”) to start/stop recording of video
RC9_OPTION = 167 (“Camera Zoom”) to zoom in and out
RC9_OPTION = 168 (“Camera Manual Focus”) to adjust focus in and out
RC9_OPTION = 169 (“Camera Auto Focus”) to trigger auto focus
Warning
A8 does not support zoom at 4K recording resolution
Firmware Updates and Configuration
Ensure the camera gimbal is running a recent firmware:
Download, install and run “SIYI PC Assistant” which can be found on any of the links below. Also download the “Firmware Pack” which includes the latest firmware for the camera and gimbal
Connect the camera gimbal to a PC using a USB cable
Power on the camera gimbal
Open the Siyi PC Assistant and check the gimbal and camera firmware versions
The gimbal version appears on the “upload” page. For ZR10 use 0.2.1 or higher. For A8 use 0.1.7 or higher.

Upgrade the gimbal firmware by pushing the “getfilename” button, select the “xxx Gimbal Firmware xxx.bin” file downloaded above and push the “upgrade” button
The camera version appears on the “gimbal config” page.
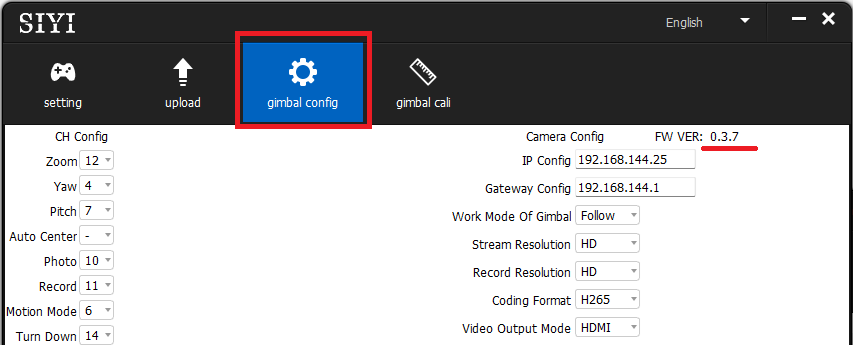
Upgrade the camera firmware:
Power down the camera gimbal and remove the SD card
From the Firmware Pack downloaded above, find the file named “xxx UpgradeSD.bin” and copy it to the top directory of the SD card
Place the SD card back in the camera gimbal
Power on the device, connect with the Siyi Assistant and confirm the version has been updated
Ethernet Connectivity
Instead of using a UART serial connection to control the gimbal, an Ethernet virtual serial connection may also be used, as well as transmitting a video stream from the camera.

An example of the setup of the gimbal in a networked ArduPilot vehicle system is detailed in Ethernet Connected Vehicle Example but in short, to control the gimbal over Ethernet:
Connect the gimbal and autopilot using an ethernet adapter
Ensure the autopilot and gimbal are on the same subnet (e.g. the first 3 octets of the IP address match, 4th octet is different)
The gimbal’s IP address can be set using the Siyi Assistant software (see image below)
Set the autopilot’s NET_ENABLE = 1 and reboot to enable networking
Set the autopilot’s IP address using NET_IPADDR0, NET_IPADDR1, NET_IPADDR2, NET_IPADDR3 (e.g. 192.168.144.14)
Create a serial connection over Ethernet
Set NET_P1_TYPE = 1 (UDP Client) and reboot the autopilot
Set NET_P1_IP0, NET_P1_IP1, NET_P1_IP2, NET_P1_IP3 to the gimbal’s IP address (e.g. 192.168.144.25)
Set NET_P1_PORT = 37260 (port that Siyi gimbals listen for commands on)
Set NET_P1_PROTOCOL = 8 (Gimbal)
To view the Siyi camera’s live video over Ethernet use the Siyi Assistant to set the “IP Config”, “Coding Format” and Video Output mode as shown below. Note that the IP’s first three numbers should match the telemetry system being used (e.g. Herelink, Siyi MK32, etc) or PC the camera is connected to. The image below shows the default IP address for Siyi gimbals.

The video is available using an RTSP URL which can vary by camera type. Note the URL’s IP address should match the camera’s IP address that was entered into the Siyi Assistant above:
A8, ZR10: rtsp://192.168.144.25:8554/main.264
ZT6 (IR): rtsp://192.168.144.25:8554/video1
ZT6 (RGB): rtsp://192.168.144.25:8554/video2
If connected to a PC, VLC can be used to test the feed:
Open VLC
Select “Media”, “Open Network Stream” and enter the RTSP URL

If using QGC, the live video can be configured from the “Application Settings”, “General” screen. Set “Source” to “RTSP Video Stream” and “RTSP URL” to one of the RTSP URLs listed above:

If using Mission Planner, the live video can be displayed on the Data screen by following these instructions
Downloading Images and Video
Images and videos captured by the camera can be remotely downloaded to a companion computer or PC via Ethernet using this siyi-download.py Python script.
Control and Testing
See Gimbal / Mount Controls and Camera Controls for details on how to control the camera and gimbal using RC, GCS or Auto mode mission commands.